Latest News
September 3 Meeting Report: Powering Robots
Alan Kilian spoke about power systems for robots: batteries, circuitry, motor controllers, processors, and graceful shutdown. Learn about voltage selection, battery chemistry, BMS, and EMI.
October 15: Arjun Viswanathan: Reinforcement Learning for Multimodal Locomotion
Arjun works on reinforcement learning for robot behavior at Boston Dynamics. He did his MS in Robotics at Northeastern's Silicon Synapse Lab, teaching the Husky-Beta legged-aerial robot to cross rough terrain with hierarchical RL — learning not just how to walk, but which mode of locomotion to use at all.

November 12: Yun Chang: Robot Scene Understanding for Extreme Environments: from subterranean to heavy equipment
Yun spent a decade at MIT earning a Bachelor's, Master's, and PhD, working in the SPARK Lab under Professor Luca Carlone. The research centered on robot perception — compressing the world into representations a machine can act on. Yun is now co-founding a stealth startup bringing autonomy to the large machines that run society's infrastructure.
June 11: Ankush Dhawan: Meet Pupper, the Open-Source Robot Dog
Ankush is a PhD candidate in Robotics at Stanford University. Meet Pupper: an open-source quadruped robot built at Stanford that can walk, see, listen, and respond to the world around it. Born as a student project and now in its third generation, Pupper has become the centerpiece of Stanford's CS123 course, a teaching platform for AI-enabled robotics, and through the Dr. Pupper project at Stanford Medicine, a companion for children recovering in the hospital.
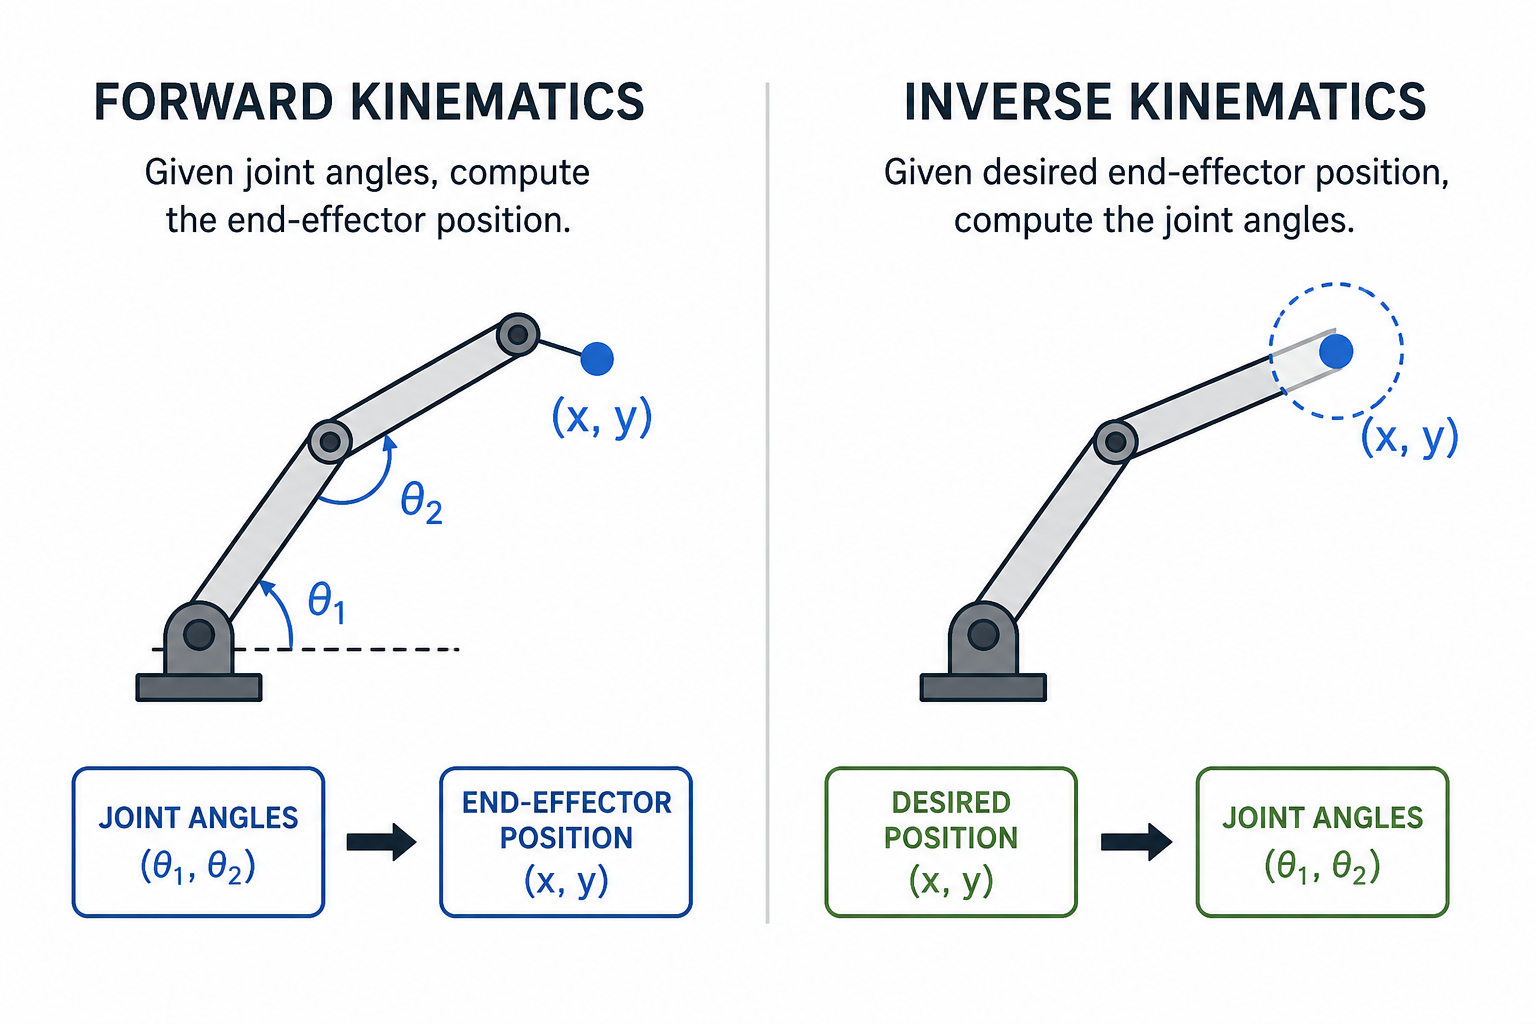
Aug 6: Shivam Chopra: Forward and Inverse Kinematics
Shivam is a Senior Medical Device Engineer and Subsystem Technical Lead at Dexcom, where he works on next-generation wearable platforms. Every robotic arm faces the same two fundamental questions: given these joint angles, where is the end-effector? (forward kinematics) — and the harder one: given a target, what joint angles get me there? (inverse kinematics). The math behind both questions is something every roboticist eventually has to reckon with, and this talk is a ground-up walk through it.

July 9: Isaac Vandor talk about maritime robotics
Isaac Vandor is the developer and maintainer for the software running on famous underwater vehicles like Alvin and AUV Sentry. Isaac will talk about his work and experiences with underwater maritime robotics.

Meeting Report: Chris Lai on Kalman Filters
Chris Lai and the team from gave a rapidfire talk teaching us about Kalman Filters. Kalman filters are a constant source of confusion. No one doubts their value but it's easy to get lost in trying to understand the math or the right way to use them.
May 7: Adam Ring talk about simulation
Adam Ring will give the talk about simulation in robotics. In this talk, Adam will discuss how the right simulation approach can accelerate development, improve safety, and reduce costly real-world failures.
September 3: Alan Kilian talk: Powering Robots
Alan Kilian, a long time software and hardware person with a lifelong passion for Robotics will speak about aspects of power for robots. Batteries, Measurement, Circuitry and more.

Meeting announcement for April 2: Kalman Filters
Chris Lai leads the Beaver Works Summer Program at MIT. Chris will discuss the motivation behind the Kalman Filter, and describe why (and most importantly) how it is used.

Meeting announcement for March 5: Tom Ryder on current trends in Robotics
We are fortunate to have Tom Ryden, Executive Director of Mass Robotics as our speaker this month. Tom will discuss current trends in Robotics Startups and the industry in general

Meeting announcement for January 8 - URDF and Vibe Coding
Monthly Meeting Announcement January 8 at A2

Meeting notes from December main meeting
Thoughts about our December meeting

2026 Meetings and Talks
Speakers for March, April and June 2026
Meeting announcement: David Dorff on Affordable Biometric Robot Hands: October 9 at 7:00pm
Featuring talk by David Dorf about "Affordable Biomimetic Robot Hands"
November meeting update
This was our most attended meeting to date. Skyler gave a great presenetation about his work applying neural nets to a robot arm. The neural net was trained by watching videos he made of the arm working under remote control
Introducing Lightning Talks
Our monthly meetings will now include a section of lightning talks. Anyone can self-nominate for a talk. We have time for up to three of them each meeting. This is a really quick 5-10 minute talk presented by one of us. Topics are anything robot-related where you explain something you know, or know how to do, or show, so we all learn from each other.

Introducing Hands-On Meetings!
Hands-on meetings are coming, starting on Oct 23. The usual place and time. Some of us will bring some partial robots or other widgets from our workshops and if you acquire a robot or robot kit before and want help building it or debugging it, bring it along. It will be a two hour meeting, without an agenda!
Third BRH Meeting October 9 2025
Featuring a talk discussing novel methods for tackling these issues with 3D printing flexible materials and biomimetic design
Meeting Announcement for December 11 at 7:00pm
Featured Talk: Joel Grimm and Christopher Lai will introduce us to the Autonomous RACECAR at MIT's Beaver Works Summer Institute
Meeting Announcement: Fourth BRH Meeting November 11 2025
Featured Talk: AI for generalized robotic manipulation. Learn about the foundational research around diffusion, VLAs and VLMs, and see a demo of Hugging Face's Lerobot platform for training models at home for under $500.
Become a member! Get yourself on the website!
If you're not a member, it's easy to join! If you are, let's get you listed on our member directory! If you have a cool project, we would love to showcase you on our site.

Talk: Space Station OS
The talk at our next monthly (Sept 4) will be "Space Station OS - Open source OS for next generation space stations using ROS2"
Montlhy Meetings
As we are still a very new club we are still figuring out how our meetings work. Here is our current approach. We meet about once a month, around the first Thursday of the month. The meetings are always on a Thursday from 7:00pm to 9:00pm. Our meetings happen at the Artisans Asylum in Boston (Allston) Massachusetts.
First BRH Meeting was great!
Our first meeting ever was great fun and interesting. Buddy kicked it off with a talk about servos. And several shows and tells!
Second BRH Meeting September 4 2025!
Our second meeting has been scheduled for September 4 at 7:00pm at Artisans Asylum. We're in the process of nailing down the agenda. In the meanwhile though, you can register. Click to find the link.